One week. A new robot. A demo in Paris.
Porting the LLM cobot from a Franka to a UR5e in three days, an 11-hour solo drive, and Jensen Huang signing the robot.
GTC Paris · June 10–12, 2025
This is the story behind the LLM-powered cobot demo: how it went from a Franka FR3 to a UR5e in a week, and a surreal encounter with Jensen Huang.
One week, new robot
About a week before GTC Paris I got the news: the demo, built on a Franka FR3, had to run on a UR5e, because of Accenture’s partnership with Teradyne, to be announced at GTC.
Short notice. And I couldn’t ship the robot ahead, because I needed it for development and testing until the last moment. So the plan: develop in Munich, pack everything, drive the UR5e to Paris the day before.
- Days 1–3Onboard the UR5e
UR5e backend for the generic arm interface, hooked into the LLM loop, every skill tested end to end.
- Day 4Build a base
No drilling the GTC table. Wooden planks, robot bolted on, planks clamped down.
- Day 5Pack and drive
Rent a car, pack, triple-check. Munich → Paris alone, about 11 hours with two breaks.
- June 10–12GTC Paris
Set up during the keynote, then two days of live demos.
Three days on the UR5e
Because the robot layer was robot-agnostic, onboarding a new arm was mostly extending the existing interface. Still a lot to do.
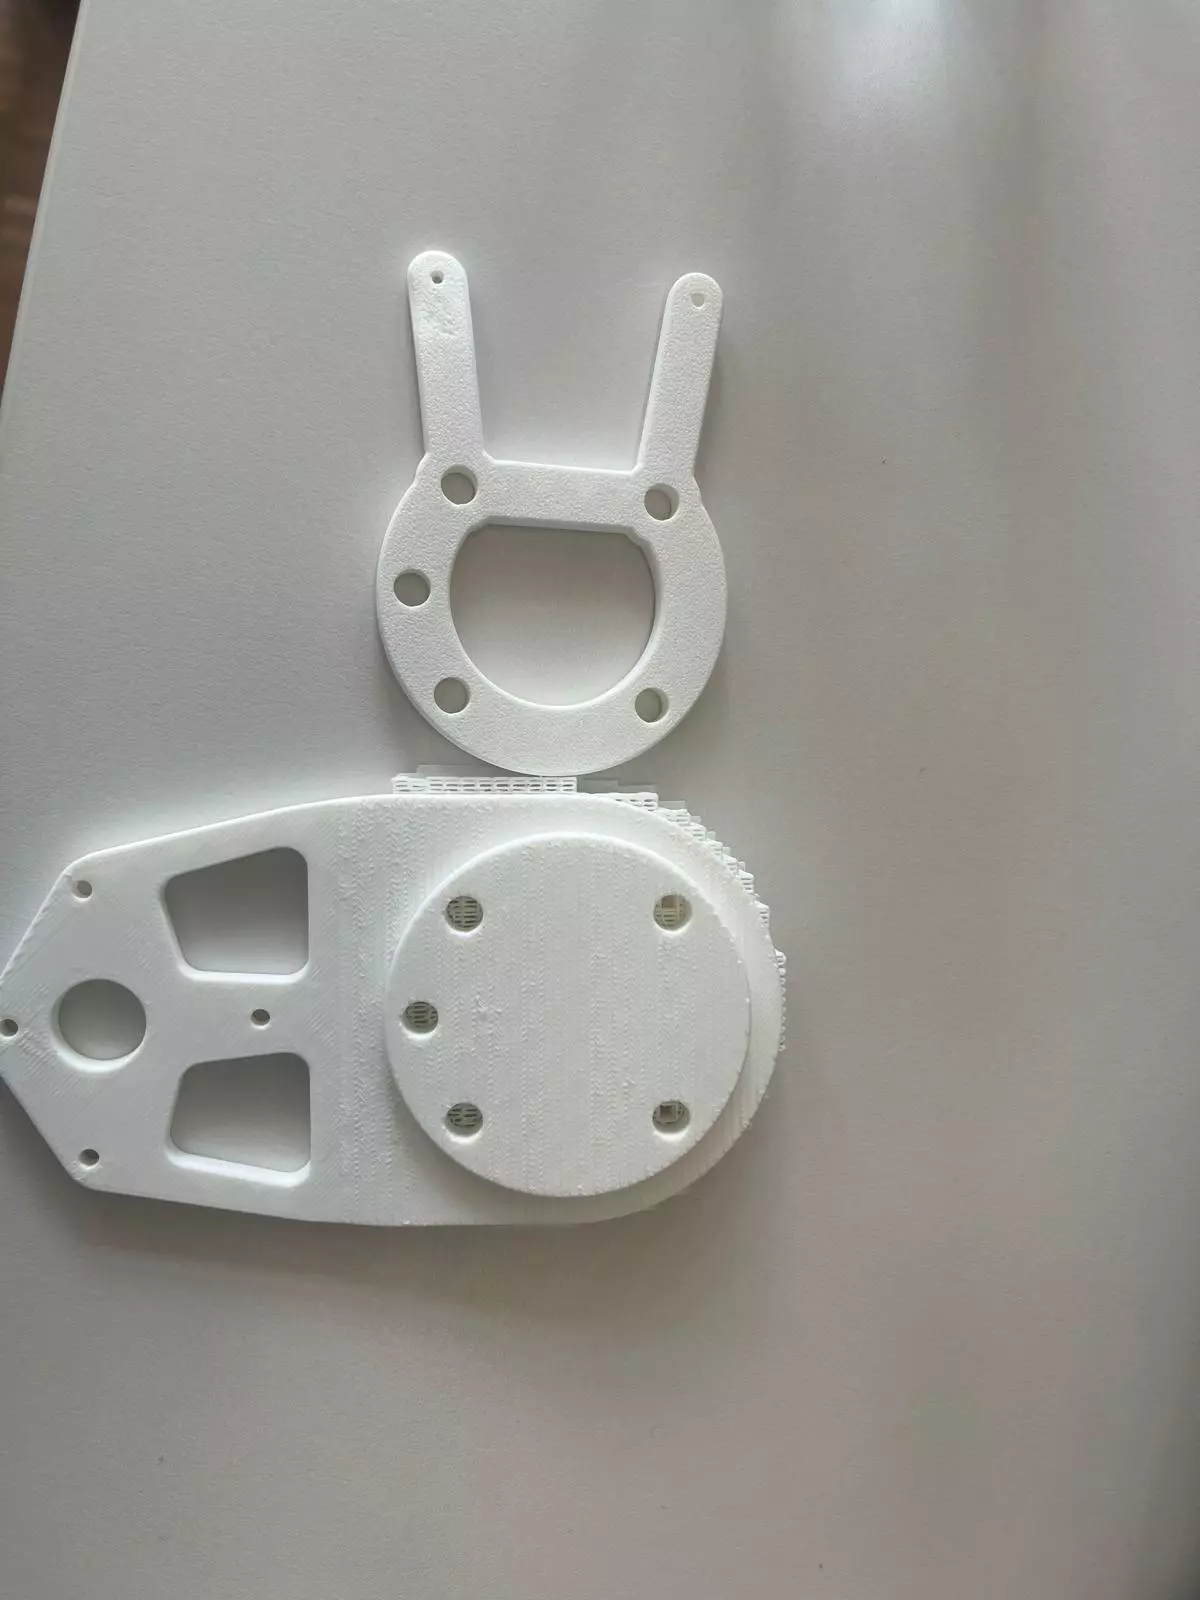
In parallel I had to solve eye-in-hand camera mounting. I didn’t design the mounts: I found two designs online, printed both and tested them on the UR5e for stability and vibration. The bigger one was sturdier and won. Then I calibrated the UR5e + RealSense with my hand-eye calibration tools.
No drilling allowed
“You cannot drill the GTC table.” So I spent another full day, with a colleague’s help, building sturdy wooden planks. The UR5e was bolted to them and the planks were clamped to the table. Rigid enough for manipulation.
A robot in the back seat
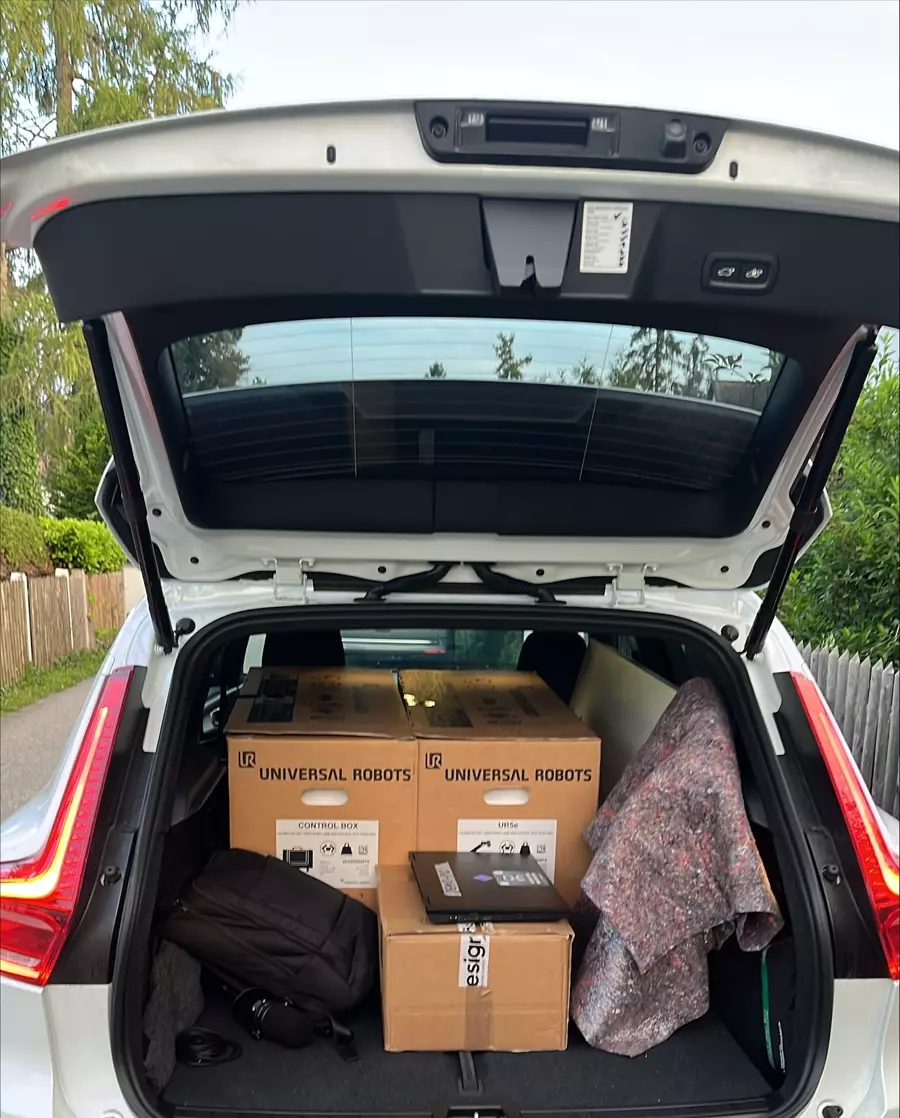
The last day was logistics: renting a car, packing the UR5e, planks, camera, cables, tools and spares, and checking nothing was missing. Then I drove alone from Munich to Paris, roughly 11 hours with two breaks, with a robot in the back and a lot of adrenaline.
Demo days
On day one, while the keynote was on, I was at the Accenture booth setting up: UR5e, camera, calibration, the LLM system. After the keynote the booth got busy fast. For two days it was a constant stream of live demos, questions about LLMs and robotics, and conversations with visitors from many industries. Exhausting, and very rewarding.
Jensen’s visit
Everyone assumed Jensen Huang would leave after his keynote. On the last day, unannounced, he started walking the expo floor, visiting booths at random.
He went to the AWS booth opposite ours. I went over, took a selfie, and took a group photo of the AWS team with him. They gave me an AWS sock as thanks. I’d also put a Rubik’s cube on our table, ready for an autograph if he ever came over. He disappeared into the crowd.
About 15 minutes later, his assistant came to our booth: “He’s visiting your booth next. Please clear some space.”
A crowd formed before he arrived. Someone had already taken my Rubik’s cube.
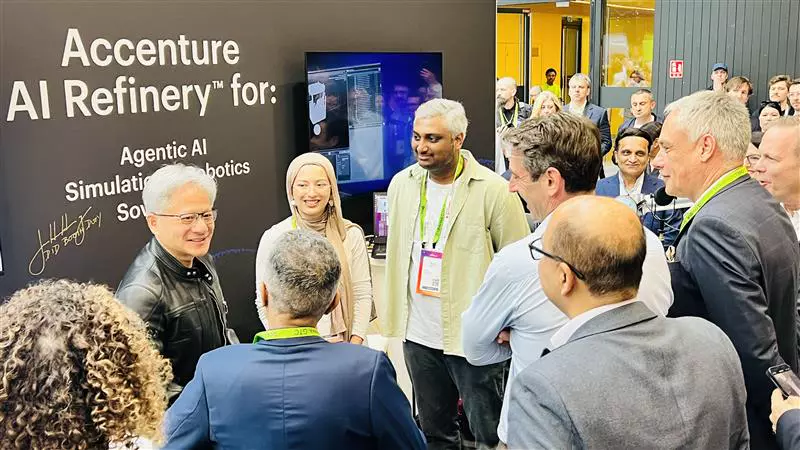
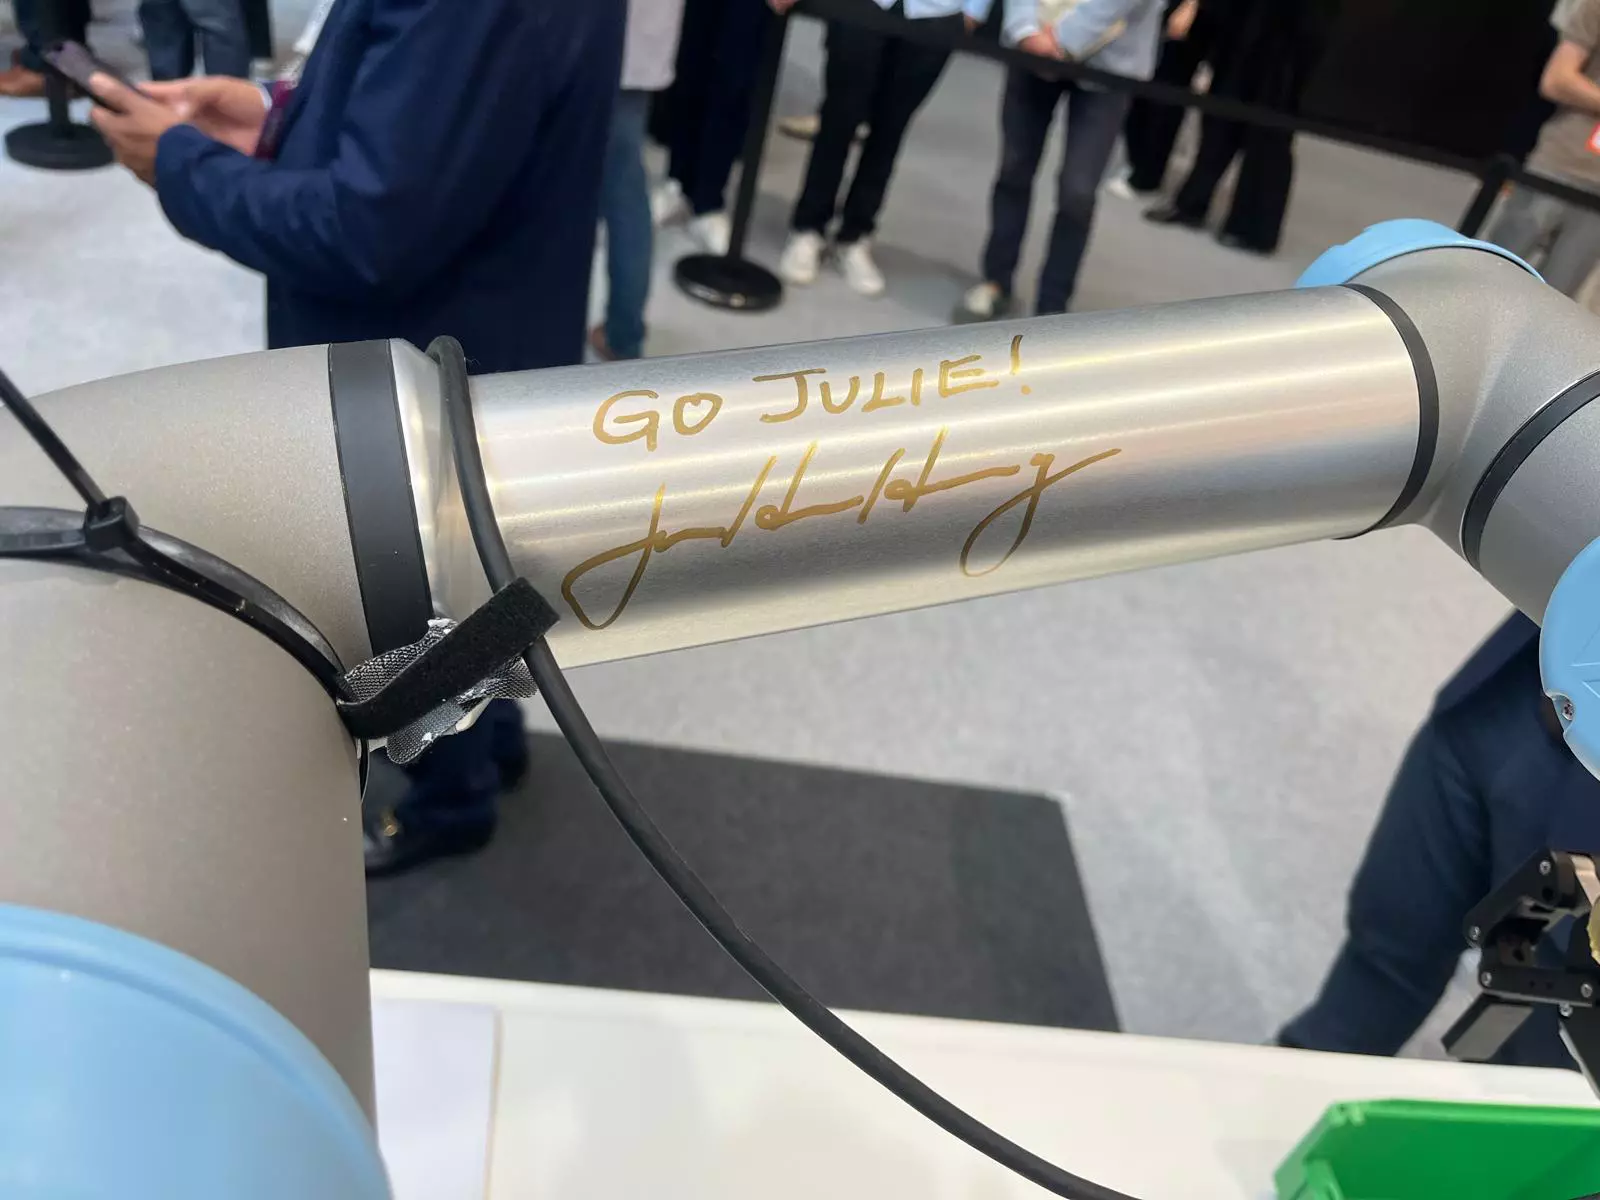
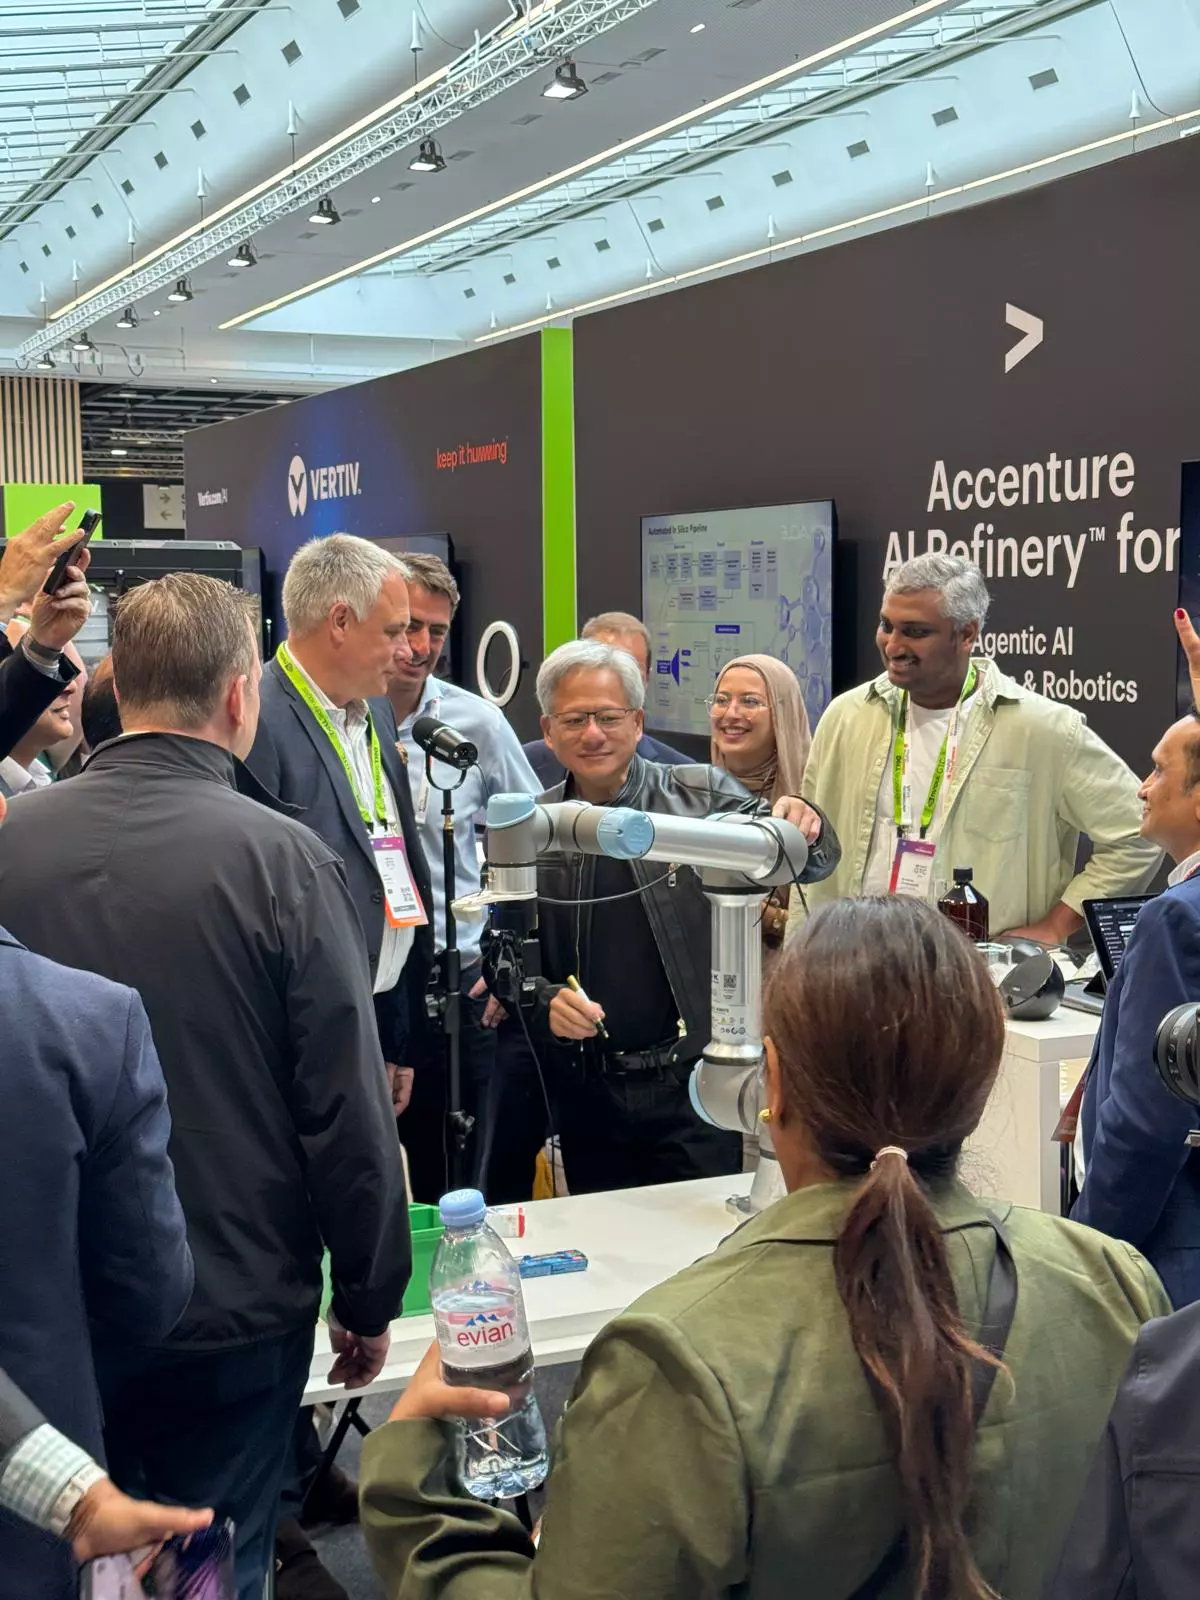
I showed him the LLM cobot demo on the UR5e and we had a short, focused chat about the system. Then he signed the UR5e, and included Accenture CEO Julie Sweet’s name in the signature.
He carries a lot of energy, and you catch a bit of it when he’s standing in front of you.
After
Walking out I felt relief, because the port, the drive, the mounting, the calibration and the endless demos all worked. And motivation, because this kind of work resonated all the way up.
The signed UR5e isn’t just a robot now. It’s a reminder of a very intense, very special week.