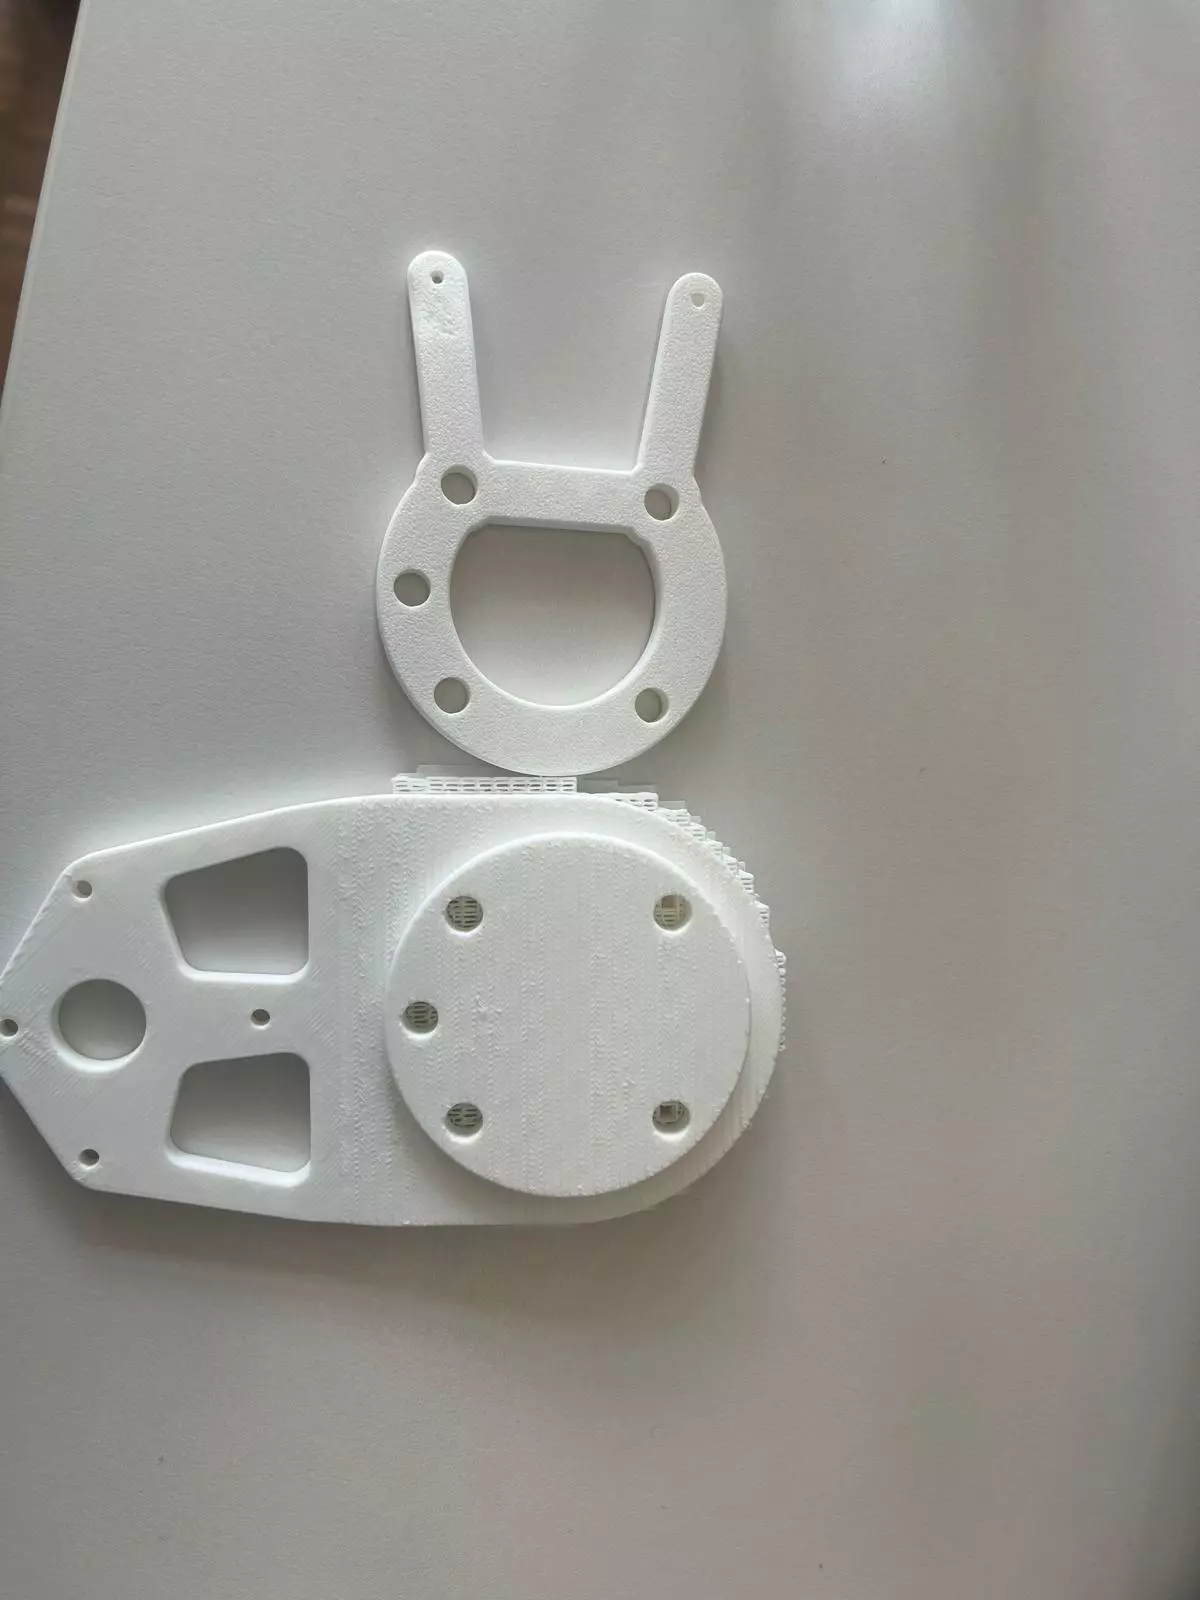
Two printed camera mounts. The big one won.Eye-in-hand mount for the UR5e
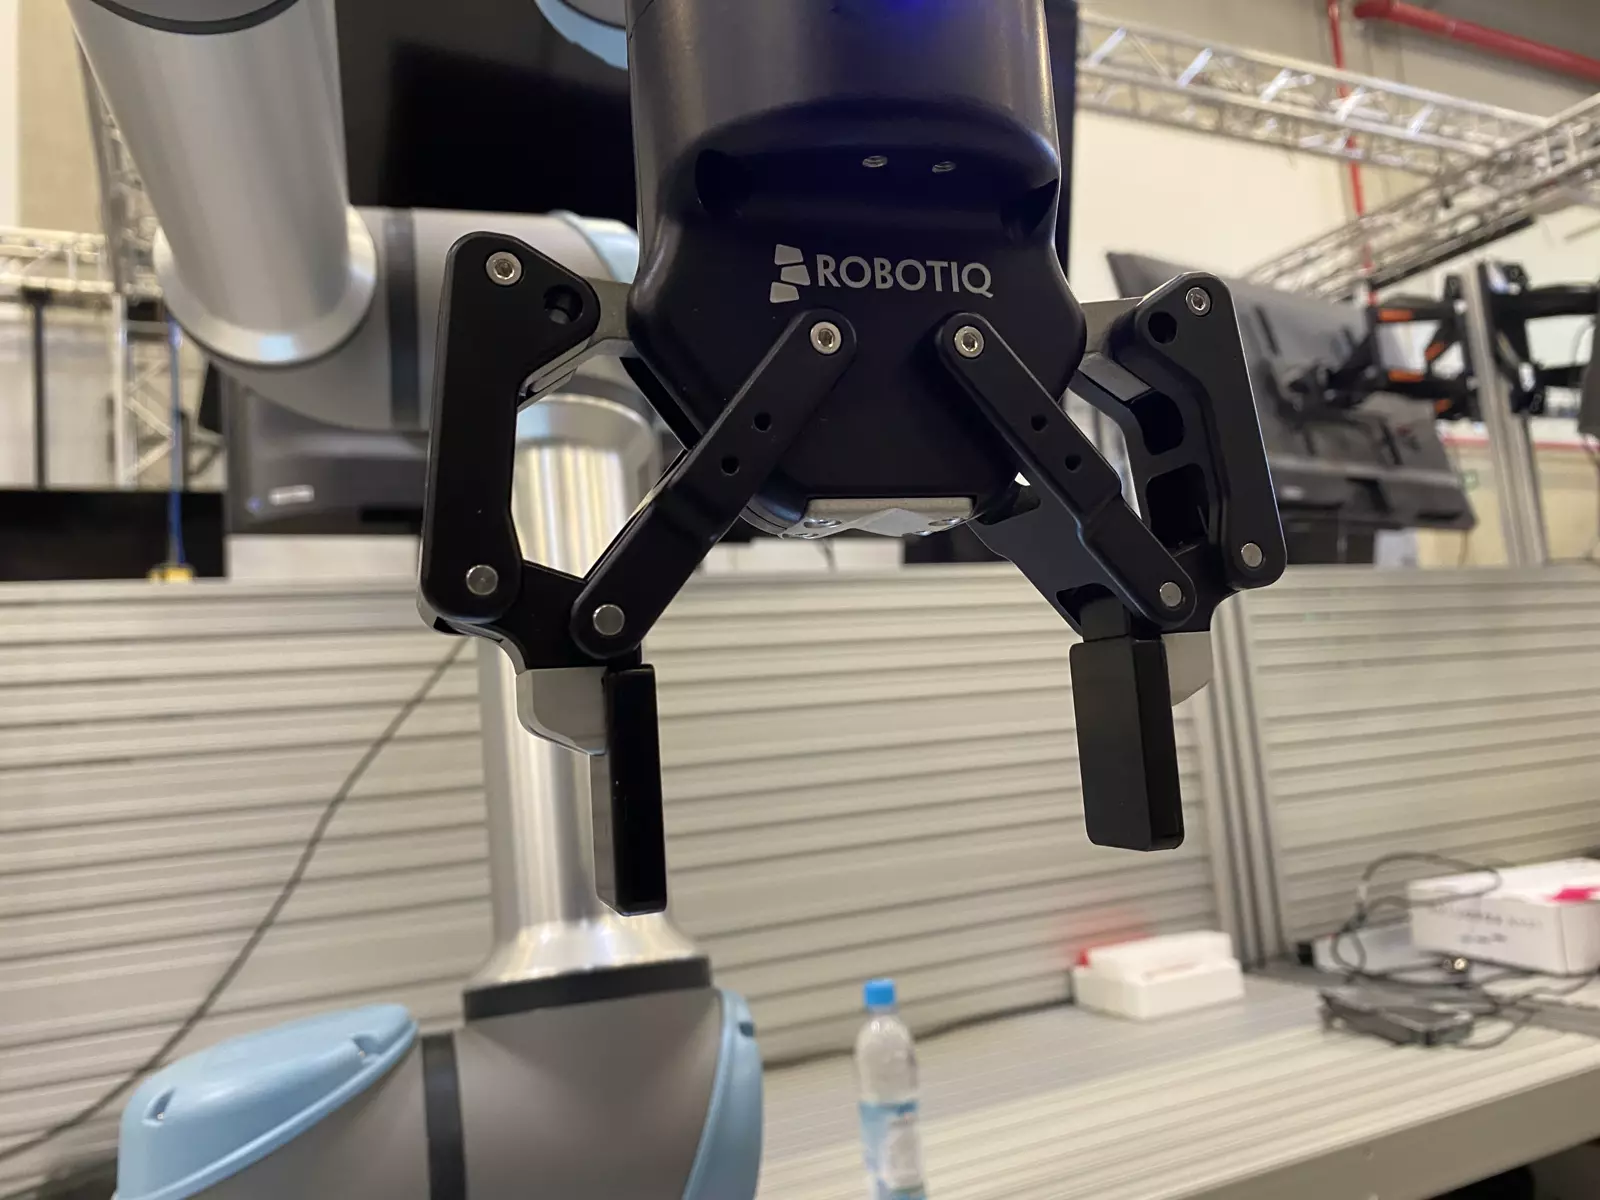
Gripper screws doubling as keypointsRobotiq gripper pose from synthetic data
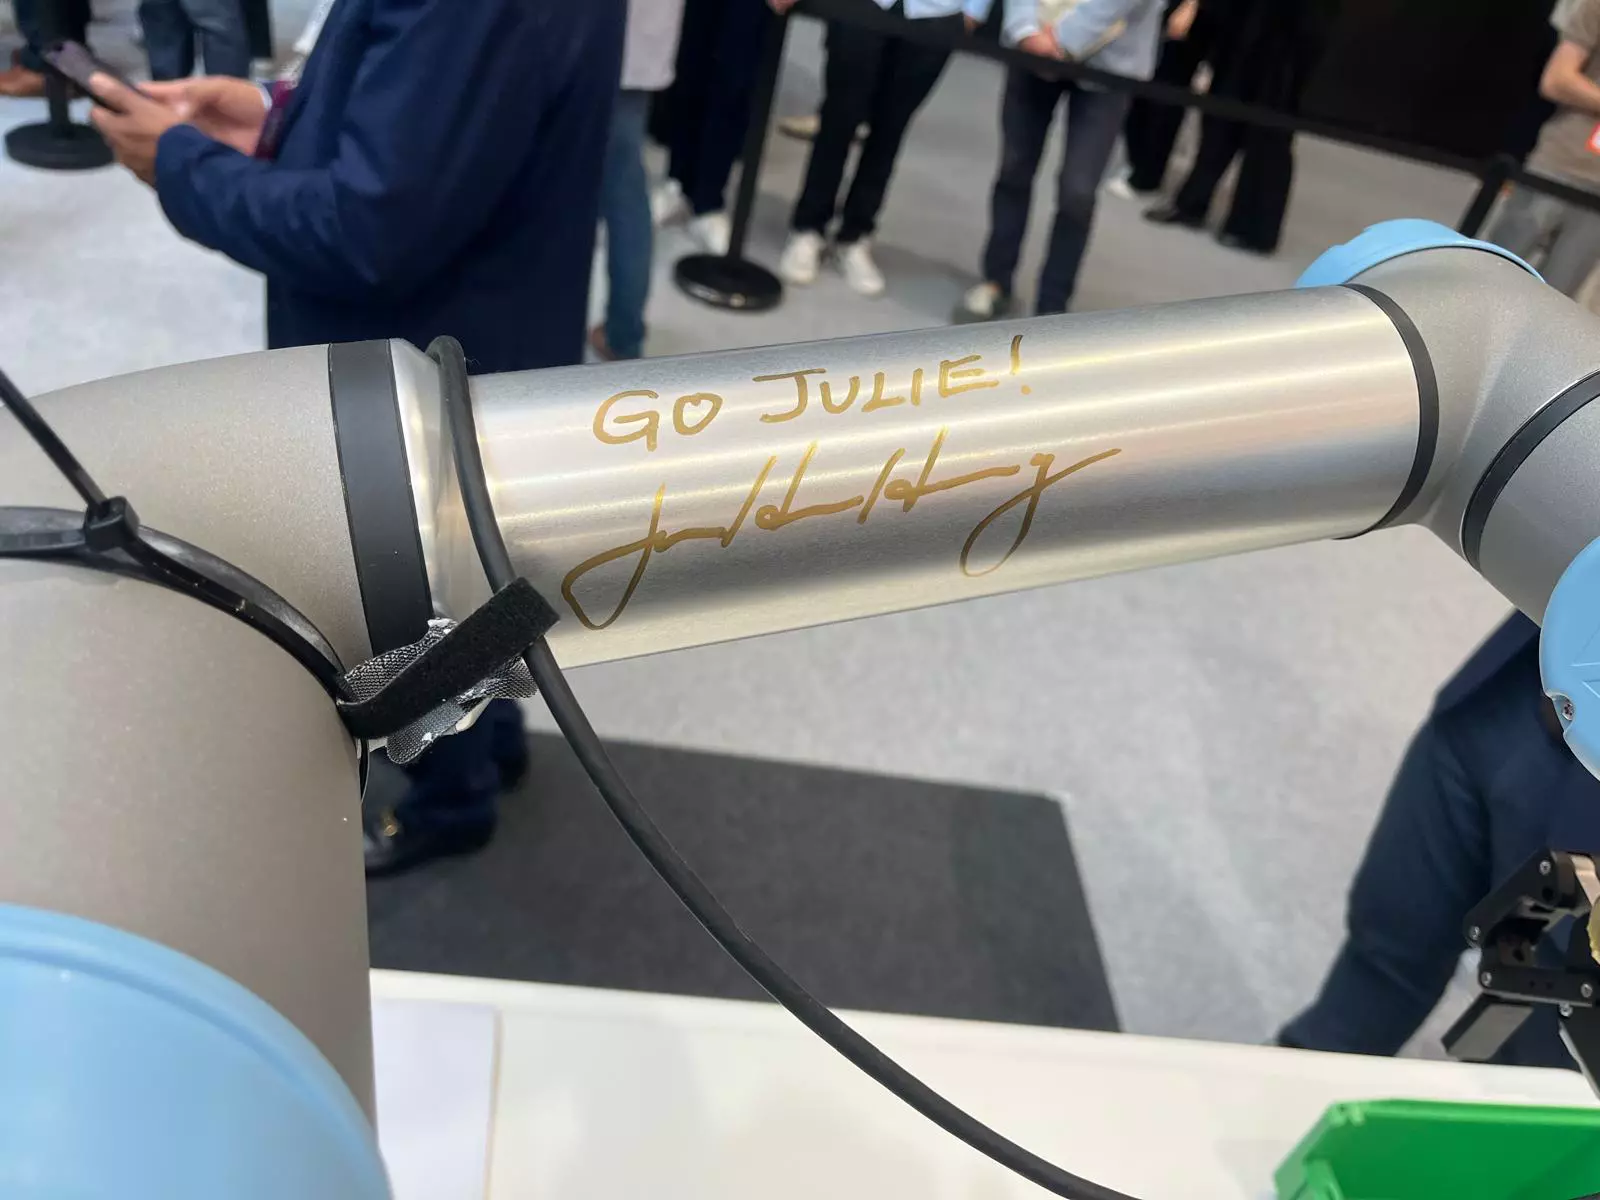
The robot, now with an autographSigned by Jensen Huang at GTC Paris
Try detecting this. It reflects the whole room.Training data for the metal-ball tracker
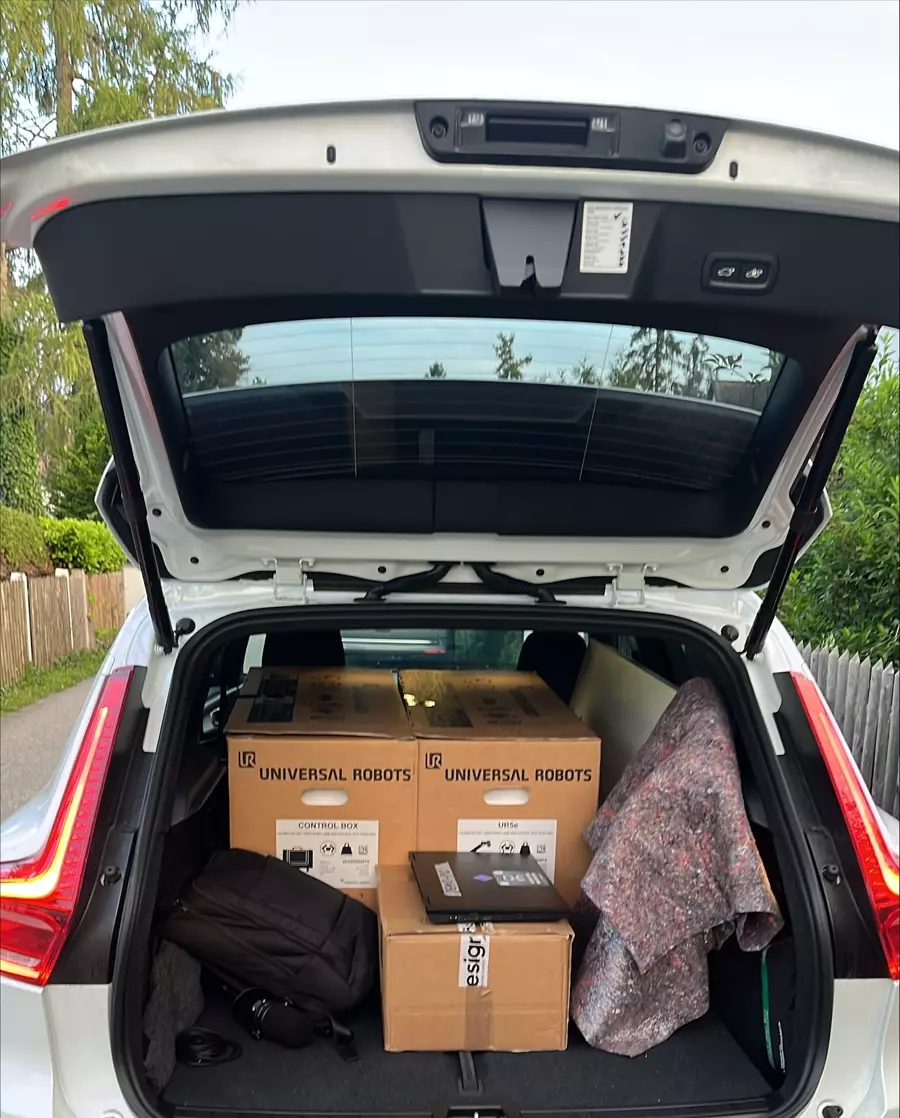
A UR5e in the boot, ready for ParisMunich → Paris, about 11 hours, GTC 2025
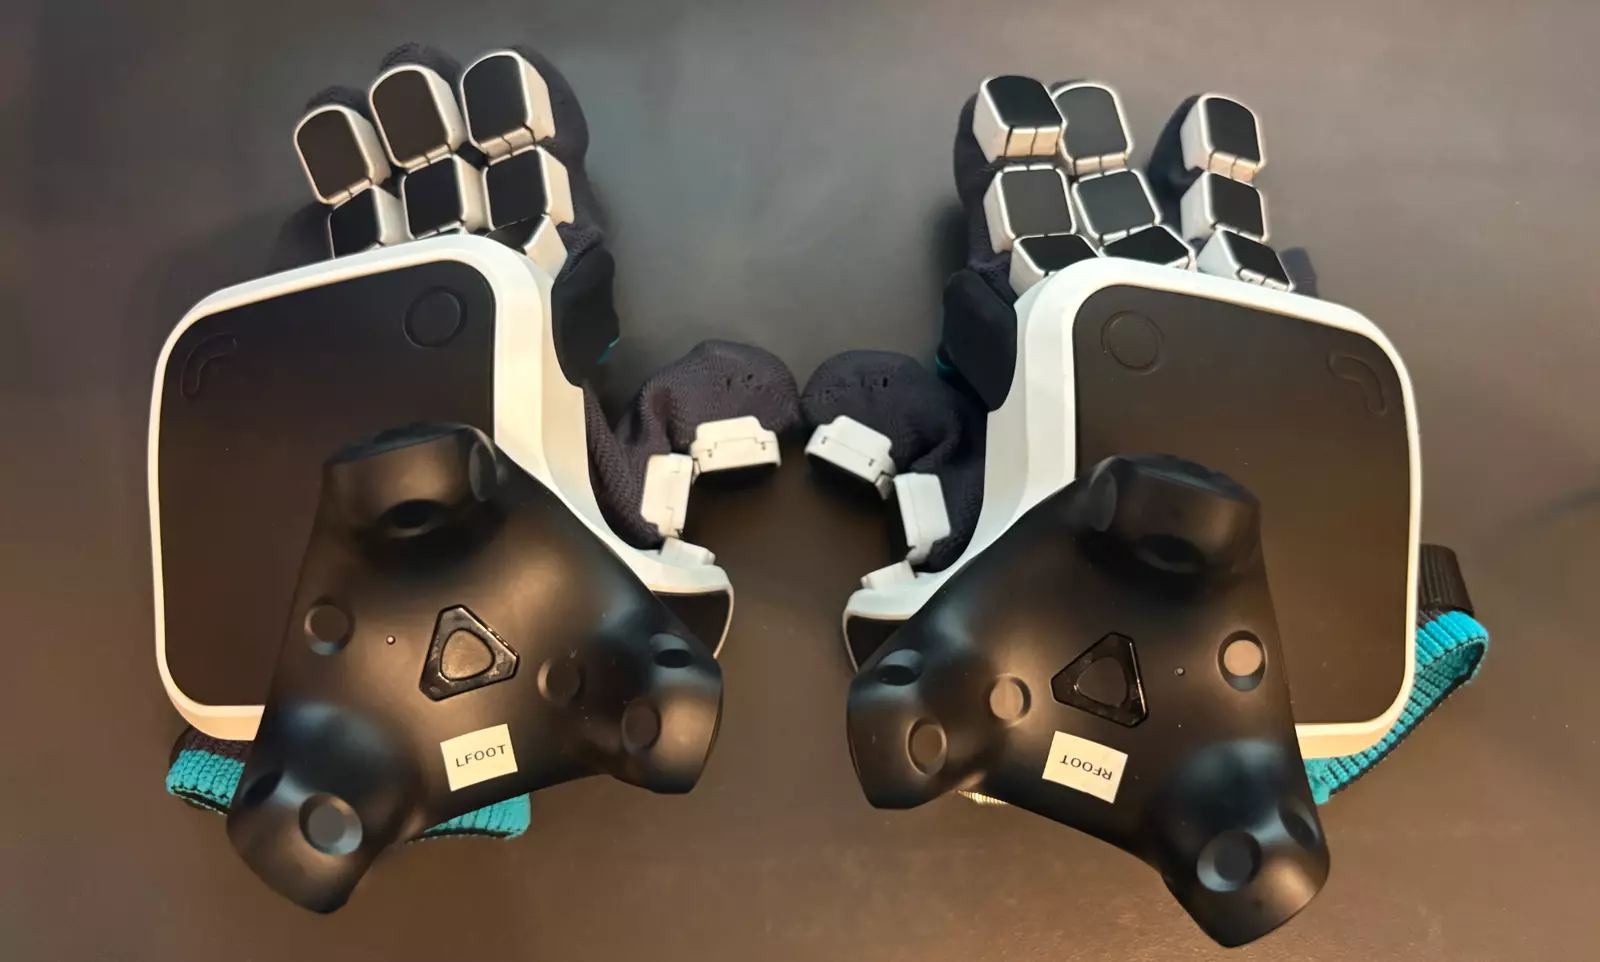
Nova2 gloves, trackers strapped onHeavy enough that you can't make a fistFlex sensors and a T265, stitched to a gloveFirst teleop glove, 2024Viper 300s following a Vive controllerQuick test before the humanoid
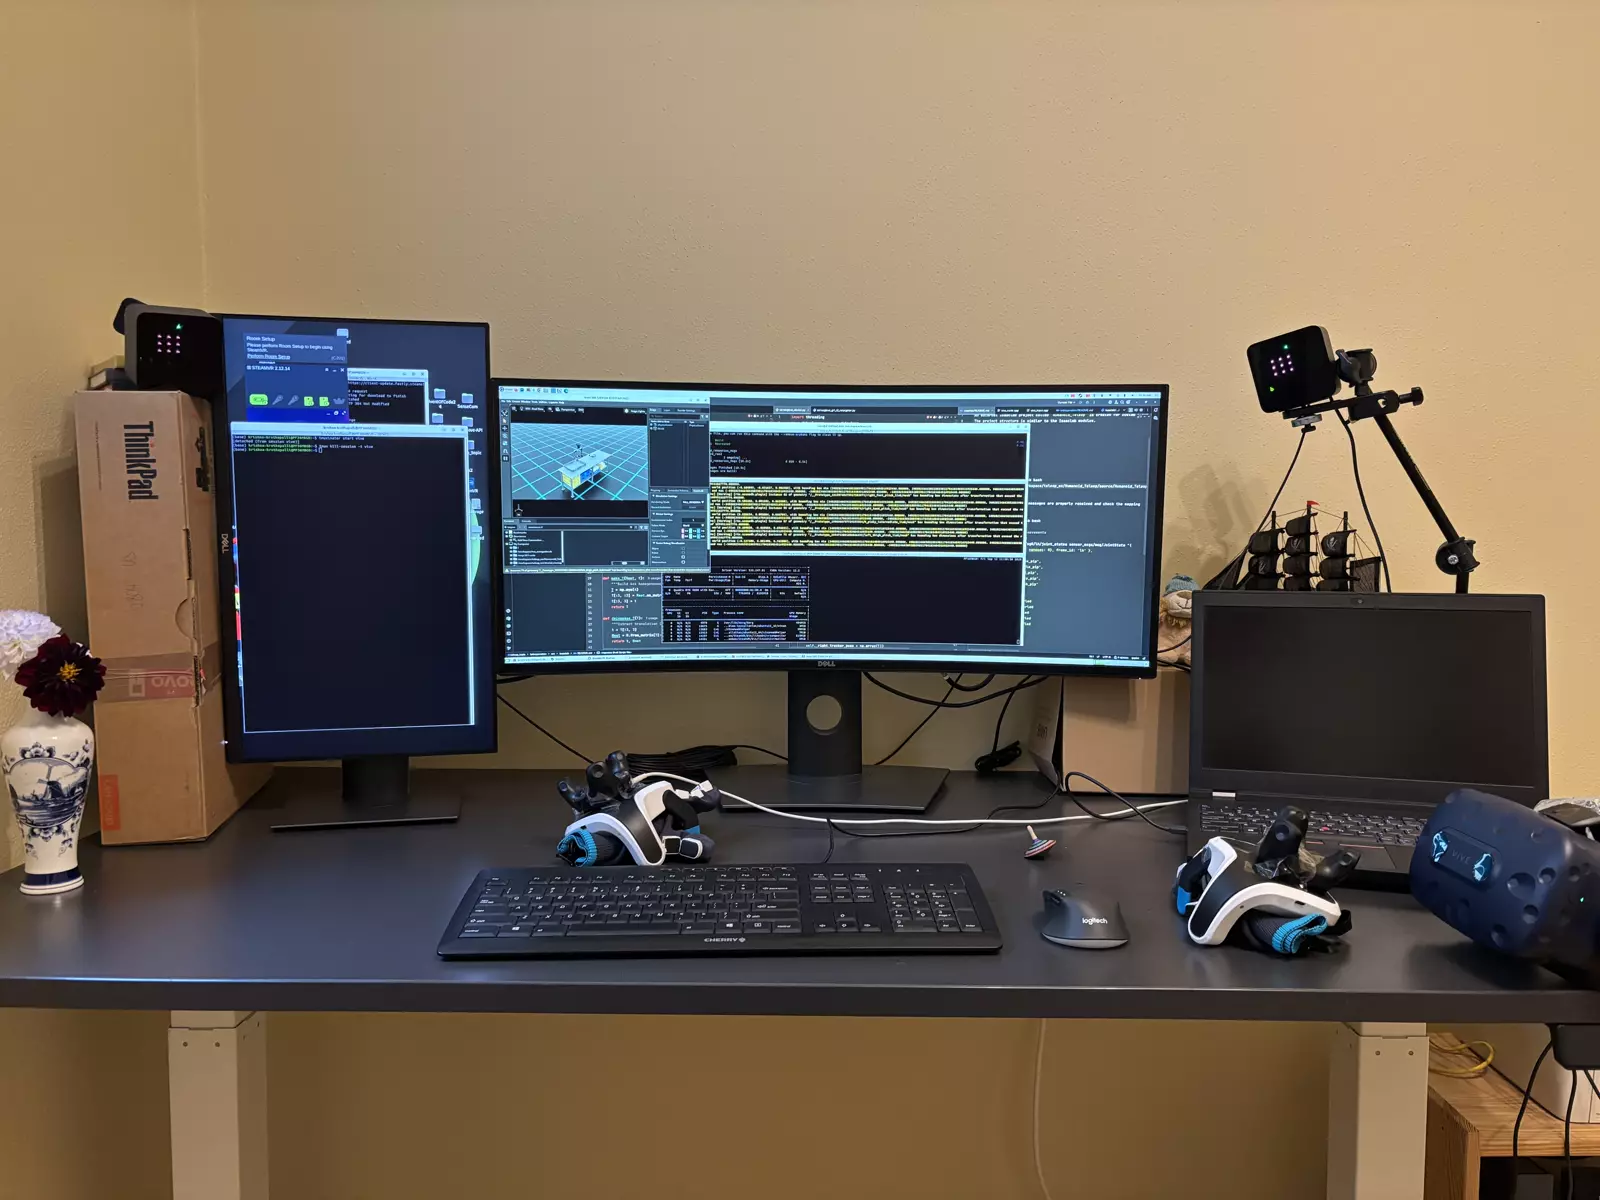
Base stations taking over the deskHumanoid teleop setup